
AMR Status Sharing: What the MassRobotics Standard Covers
Published 2026-11-02 21:12:34 -05:00 (America/New_York). Sources checked 2 November 2026. This is an editorial engineering guide; suggested tests below are not reported product test results.
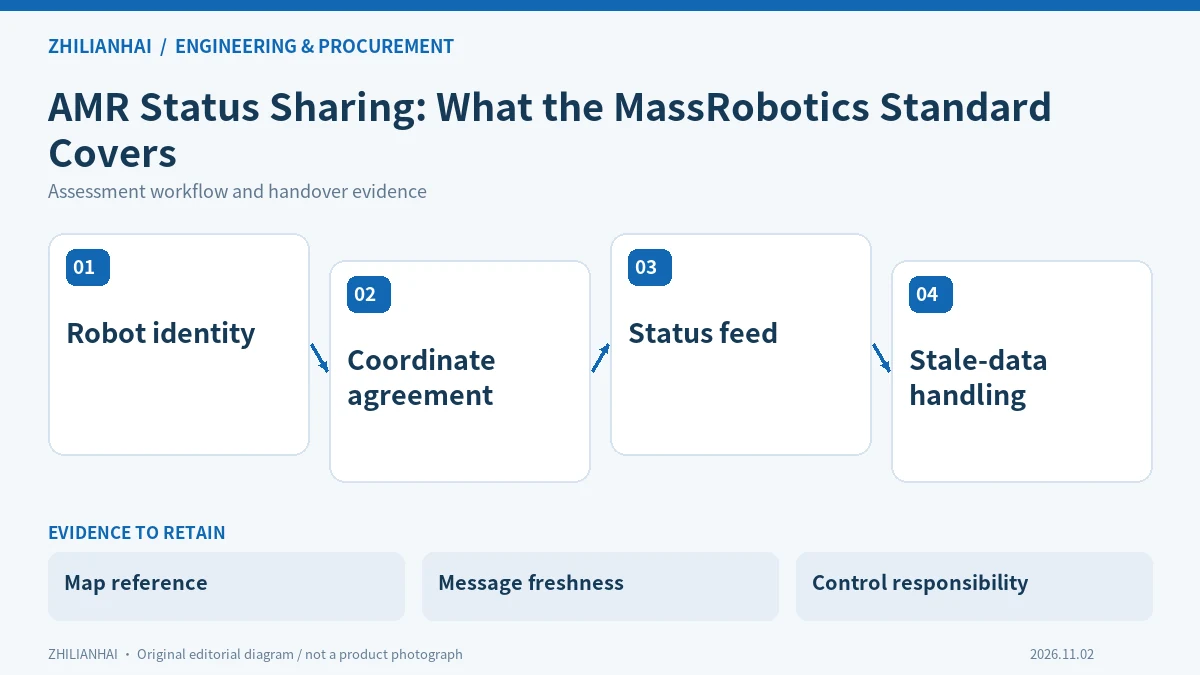
Understand what is being shared
The MassRobotics AMR Interoperability Standard repository describes information sharing between mobile robots, including location, speed, direction, health and availability. It supplies a schema, explanatory document and example sender and receiver implementations. This makes it a useful reference when different vendors’ robots need a common view of one another. It should not be presented as proof that a site already has a working multi-vendor traffic controller.
For a purchasing discussion, separate three deliverables: receiving a robot’s status, showing that status correctly and using it in an operational decision. A dashboard may satisfy the second deliverable while the first remains intermittent. A system that displays two vehicles also does not necessarily resolve which vehicle should enter a narrow passage. Ask the integrator to describe each proposed behavior and its responsible component.
Align identity and coordinate meaning
Create an inventory linking each published robot identity to a physical asset and the vendor’s own identifier. Check how identities survive maintenance, controller replacement and relocation to another building. A duplicated identifier can make an apparently healthy data feed describe the wrong machine. Include the method for retiring an asset so an old transmitter does not remain in operational views.
Map coordinate conventions before comparing positions. Establish which map, origin and orientation define the location, and how a change of site map is managed. Use recognizable survey locations or other approved references to verify that the receiver’s display corresponds to the actual floor. A plausible animation is not sufficient evidence if its axes or units are wrong.
Design a stale-data demonstration
Build a trial that distinguishes a stationary robot from a robot whose last message is old. Observe timestamps and update intervals under representative network load. Then disconnect a sender in a controlled setting and check how quickly the receiving application marks its information as stale or unavailable. The appropriate timeout is a documented site design decision, not a number to copy from a general article.
Test reconnection with the same identity and then with an intentionally different identity in an isolated environment. Confirm that the application does not blend the records or treat an old position as current. If robot status informs dispatching, show what the dispatcher does while status is uncertain. Operators need an explicit exception state and a defined escalation path.
Specify an operationally useful handover
Agree a supported schema version, identity convention, message examples, coordinate mapping and responsibility for monitoring the receiver. Preserve the software build and configuration used in the demonstration. A schema-valid message establishes structural validity; it does not establish that the measured position or reported health is physically correct.
The MassRobotics working-group material explicitly separates its interoperability work from safety standards. Keep safety validation and access-control design as their own work packages. For a mixed-fleet project, budget for adapters, map governance, supervision and exception handling, then repeat the selected tests after changes. That produces a useful shared picture of the operation without overstating what a status-sharing interface alone can accomplish.
Source and next steps
Reference: MassRobotics official AMR Interoperability Standard repository. The recommendations in this guide are our proposed procurement and validation questions, not requirements attributed to that reference. Review available robot models, compare manufacturer profiles, or contact our team with the intended task and site constraints.