
Robot Odometry: Check Pose and Twist Reference Frames
Check ROS 2 Odometry pose and twist frame contracts, retaining estimate provenance and consumer transformations before combining robot motion data. This guide concerns robot integration and delivery review. The proposed observations are editorial assessment guidance, grounded in the linked original documentation and subject to the deployed version. They do not describe an on-site test of a particular machine or establish whole-system acceptance from a single interface response.
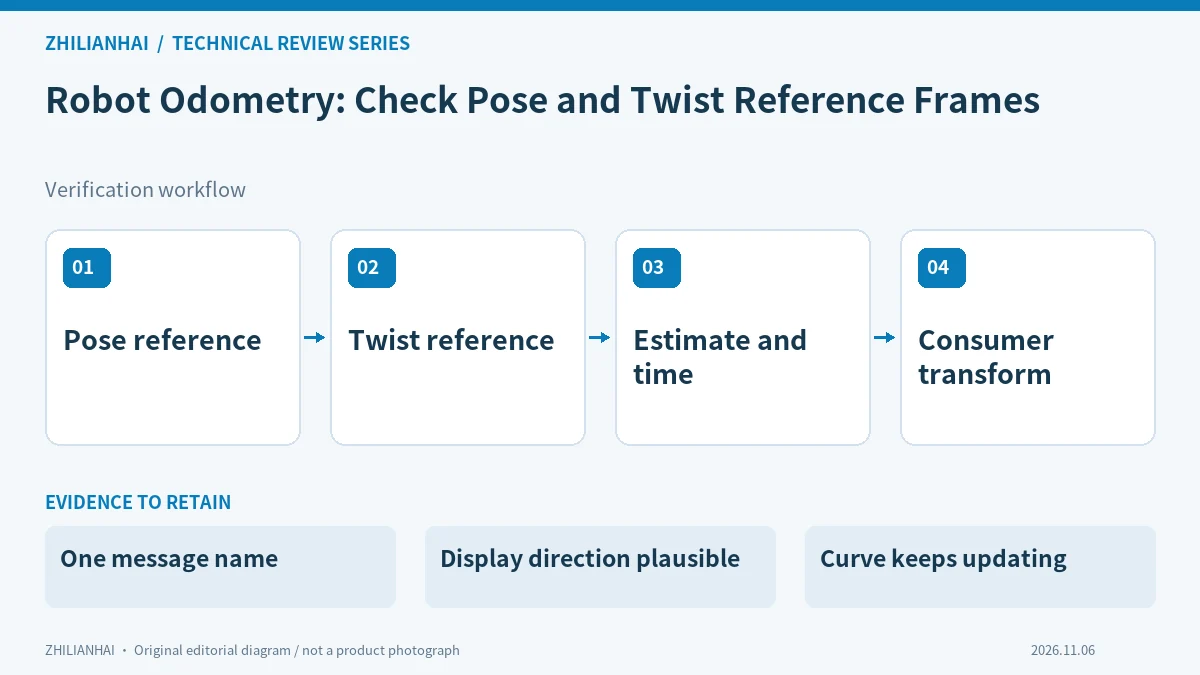
State pose and twist frames separately
The definition associates pose with header.frame_id and twist with child_frame_id. Document each rather than assigning one frame label to the complete message. Retain actual samples and driver documentation so the consumer uses the supplied geometric contract instead of silently applying its own default reference to every numeric field.
For this review, identify the delivered device, software and configuration revisions first. Record unsupported, disabled and untested capabilities separately. Evidence from another model is useful context, but cannot establish what the delivered combination actually provides. Keep the original input beside the settings used to interpret it.
Retain estimator and body identity
Identify the sensors or estimation process behind the odometry and the body reference it describes. Matching odom labels do not establish a shared origin or estimator across devices. Multi-robot deployments also need namespace and identity evidence so a valid estimate from one robot is not accidentally used in calculations for another body.
Retain the original input and the reason for the decision, rather than a successful screenshot alone. Change only the variables agreed for the comparison, and keep the before-and-after configuration. List conditions that were not exercised explicitly; they should not silently become part of the accepted operating range.
Review the consumer’s transformation
When an algorithm needs pose or velocity in another reference, retain the relevant transformation and time conditions. Relabelling a string cannot substitute for a valid change in interpretation. Separate field labels, numeric values and transformation evidence, because a plausible-looking display in one motion condition may conceal a frame error that appears under another condition.
Use the three illustrated observations as starting questions, rather than as diagnoses of an installation that has not been inspected. Check record completeness, units and identity before selecting the next observation. An unresolved result is more informative than a confident explanation assembled from missing fields or unrelated test runs.
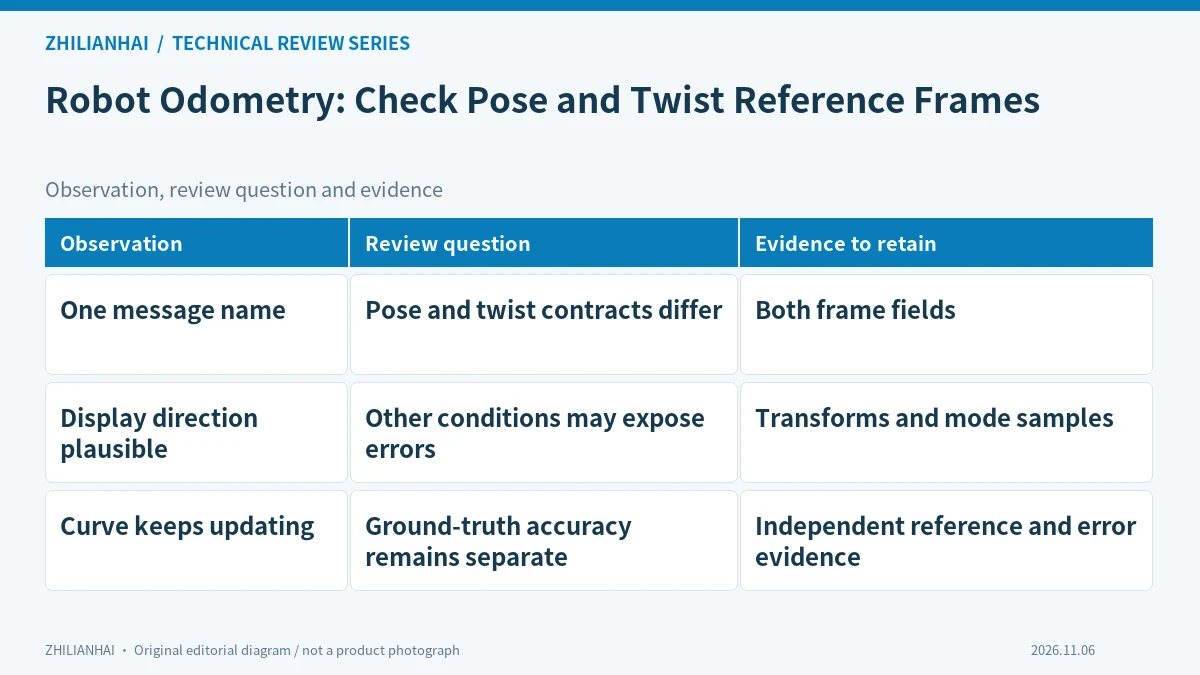
Retain covariance and timing
Keep covariance interpretation and provenance with the estimate rather than exporting only position curves. Timing also matters when comparing inputs. In isolated review, associate known inputs with consumer outputs, stating that the check concerns interface geometry and adoption. The presence of these fields alone does not establish complete localisation accuracy for the physical installation.
Let the site owner choose an approved isolated way to exercise relevant exceptions. Record normal operation, the exceptional condition and recovery separately. The purpose is to establish how the application recognises and explains untrustworthy input, without requiring production equipment to act on deliberately invalid results.
Deliver a reviewable odometry contract
Deliver frame definitions, body identity, estimator provenance, transformation rules and uncovered motion conditions. Recheck after drive or fusion changes. Odometry reports an estimate of position and velocity; continuous updates cannot establish equivalence to ground truth. Accuracy and drift need independent evidence suitable for the project’s actual operating range and reference arrangement.
Deliver the configuration, representative samples, result table and unresolved questions together. Agree who reviews subsequent changes. The receiving team should be able to select one conclusion and trace it back to its input and decision path without relying on the original author to reconstruct the missing steps.
Original documentation and further reading
Continue with related articles in this section, or use selection guides to prepare the next review. Apply the device-specific documentation and agreed operating conditions when implementing a test.