
Diagnose Missing and Disconnected Robot Transform Frames
Read the original input
Capture the incoming frame_id, requested target and query time. Topic names, device labels and frame names can carry different prefixes in the deployed system.
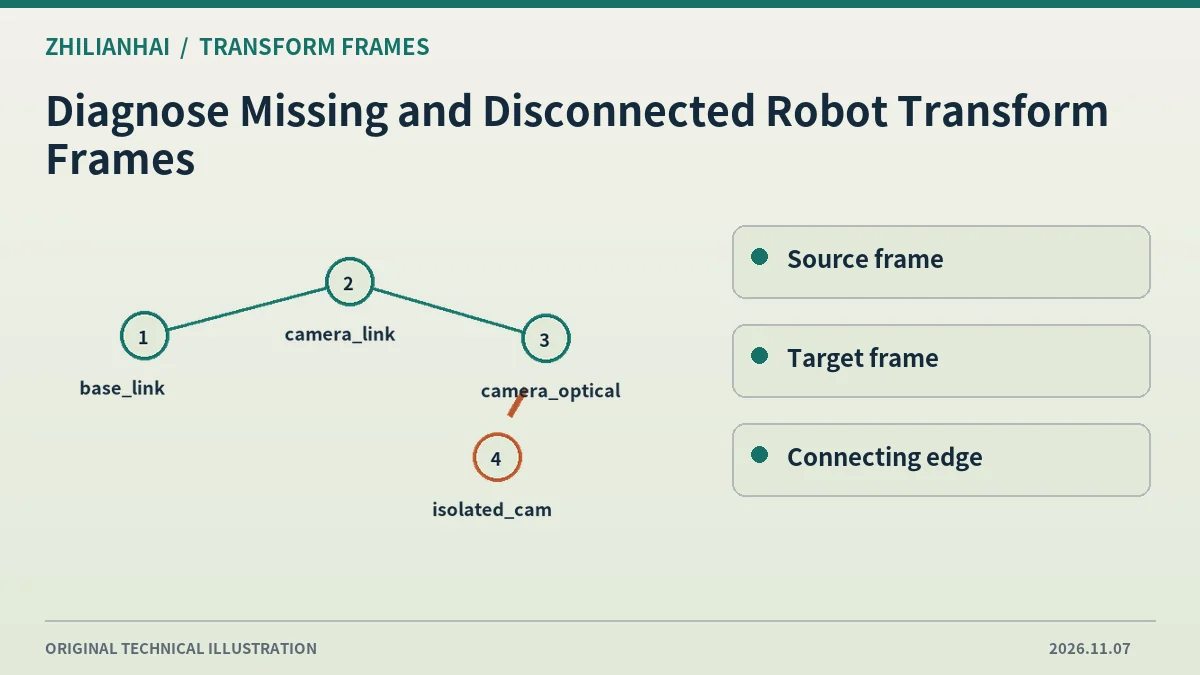
List actual frames
Inspect actual names using the transform graph or lookup tools. A near match suggests a producer or configuration issue. Trace the source before adding a second frame solely to satisfy a lookup.
Check common ancestry
If both names exist, inspect whether the branches connect. Find the missing mounting or localization edge and check whether its producer has started.
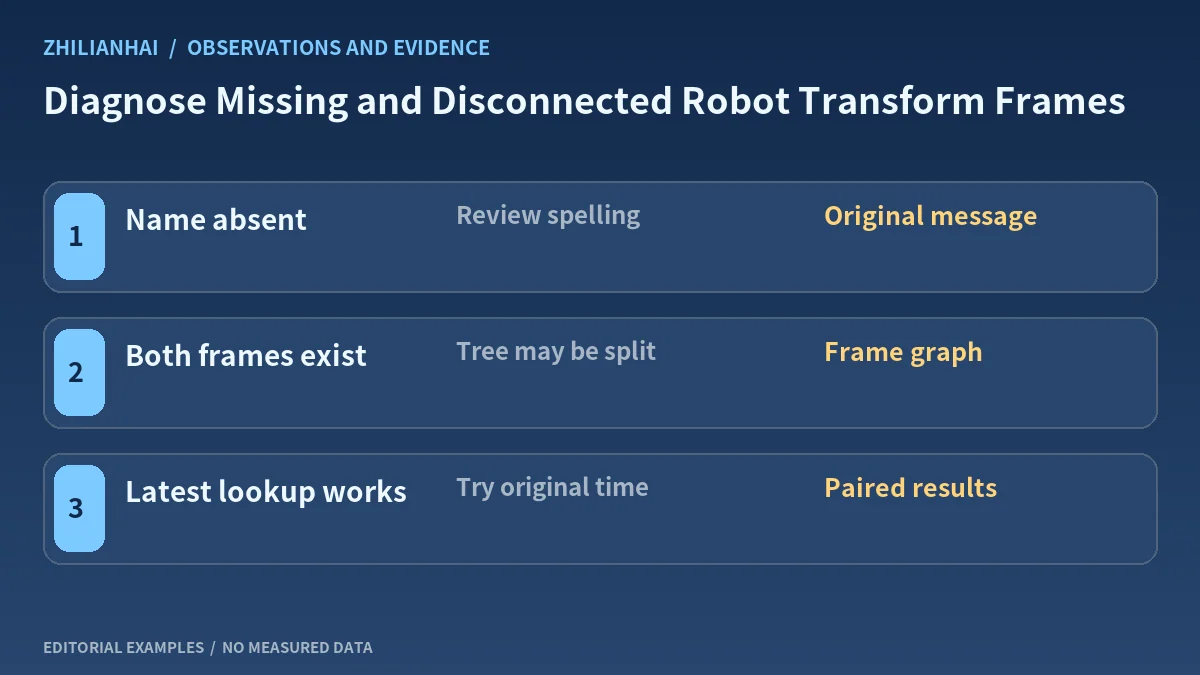
Keep a matched comparison
Retain graph and lookup evidence before and after the correction. Follow a successful latest lookup with the original measurement timestamp to detect a remaining time-coverage problem.
Recheck multiple robot instances
Start both instances in the review setup and verify prefix isolation. Document the producer responsible for each fixed or dynamic edge to make unintended cross-robot connections diagnosable.
Original documentation and further reading
Continue with related articles in this section, or use selection guides to prepare the next review. Apply the device-specific documentation and agreed operating conditions when implementing a test.