
Review Future Extrapolation for Individual Robot Measurements
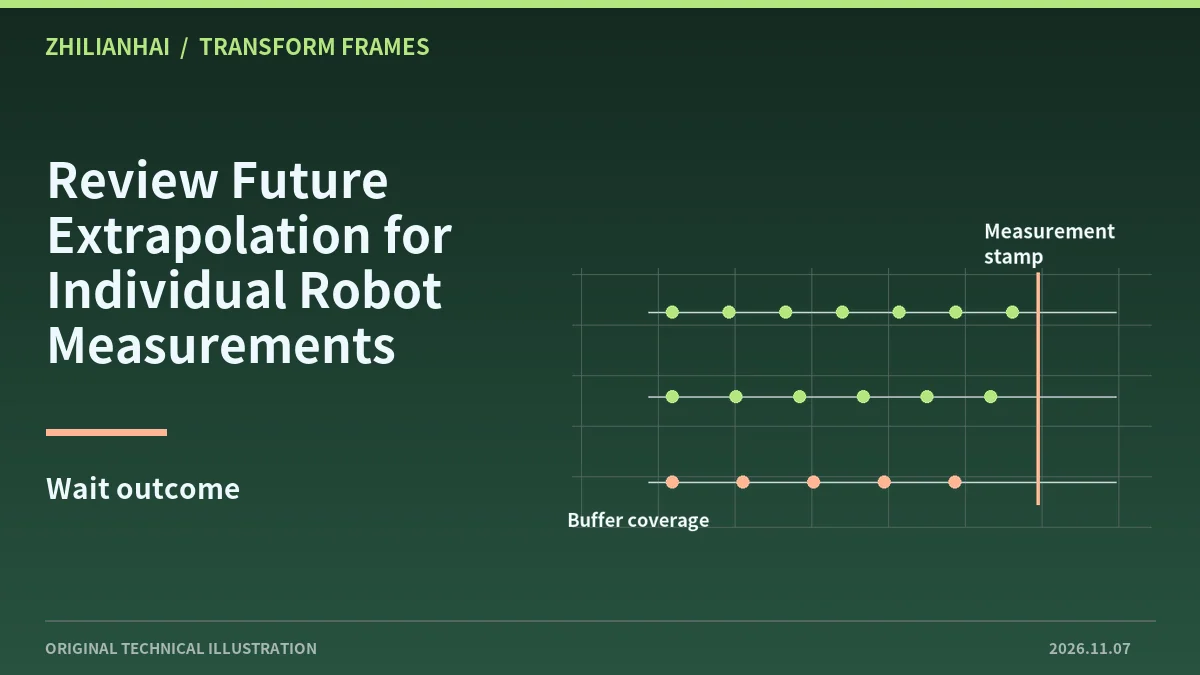
Capture the failing request
Keep source frame, target frame and the measurement stamp. Preserve the original error text, including the requested and available times, to distinguish a timing boundary from an unknown frame.
Find the limiting edge
A path may contain several transforms. One late dynamic edge can limit coverage. Inspect each edge’s sample time and arrival behavior instead of treating the freshest edge as the limit for the whole chain.
Verify clock provenance
Check simulation time, system time and hardware-converted time for compatibility. Resolve a unit or clock-origin mismatch before tuning waits or attempting to improve transport timing.
Compare waiting and alternate lookups
In replay, compare immediate lookup at the original stamp, a bounded wait and a latest query. Record pose differences. A wait only helps if the needed coverage actually becomes available.
Define adoption behavior
Record whether the consumer defers, drops or marks the affected sample. Retain reproducible failure and recovery cases, with particular attention to stale transforms during movement.
Original documentation and further reading
Continue with related articles in this section, or use selection guides to prepare the next review. Apply the device-specific documentation and agreed operating conditions when implementing a test.