
Locate Delayed Links in a Connected Robot Transform Tree
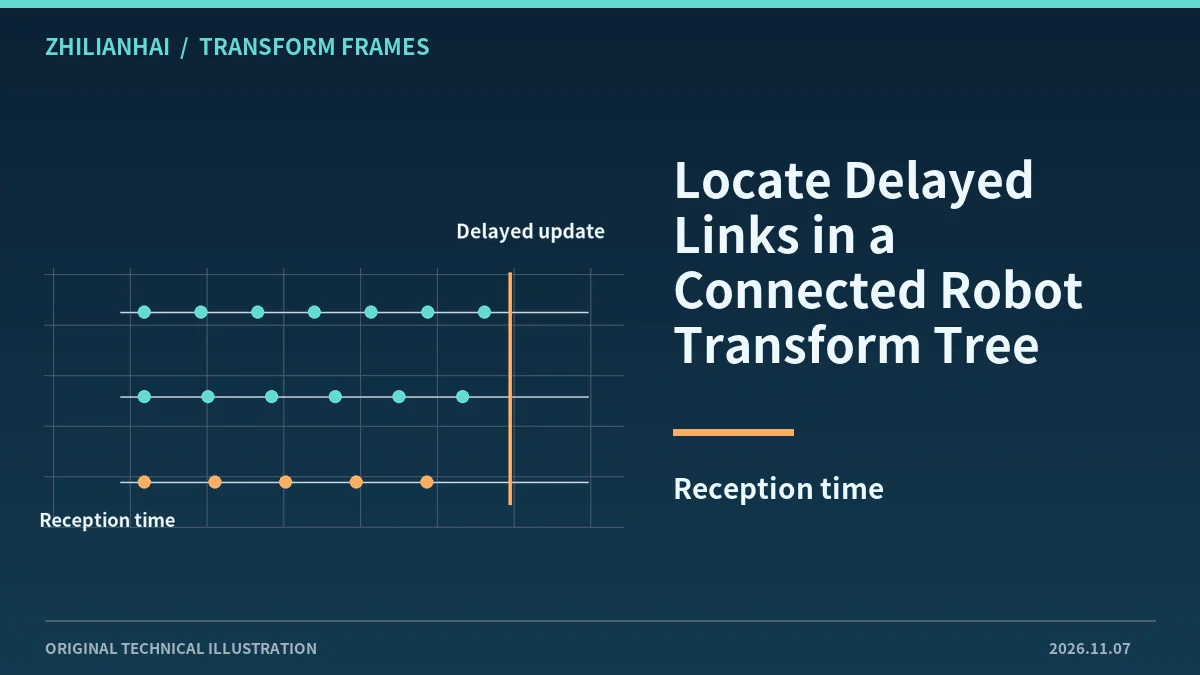
Identify the failing path
List the edges from sensor to target, distinguishing fixed mounting edges from dynamic localization or joint edges. Their expected update behavior differs.
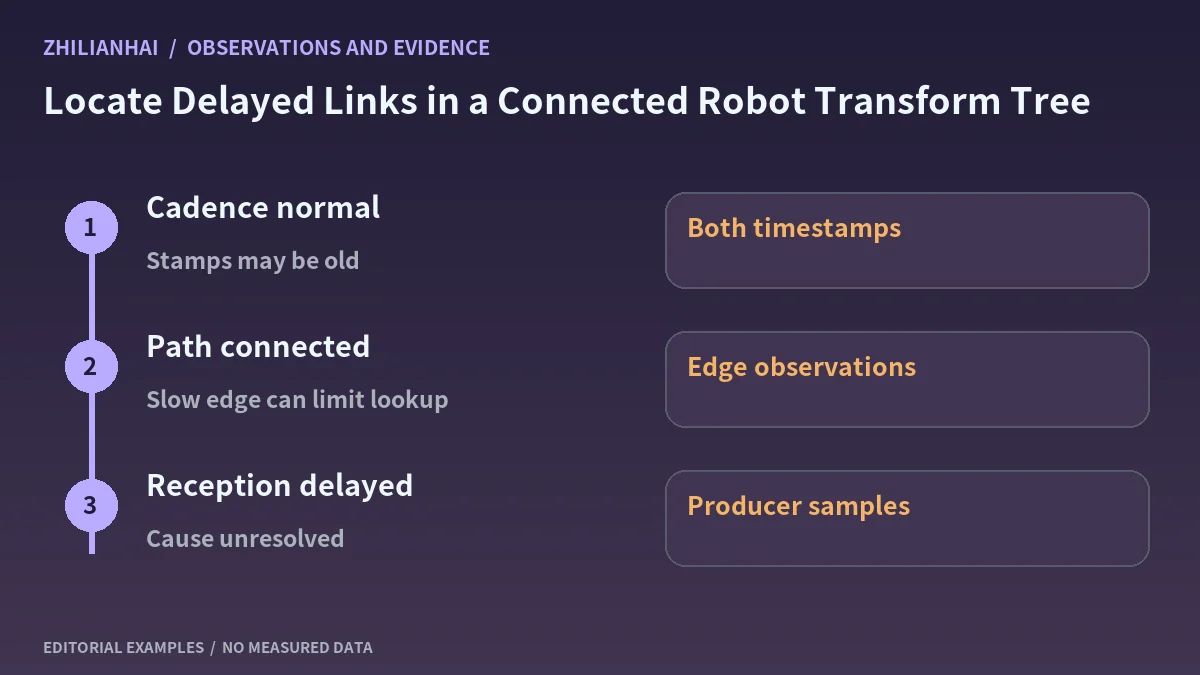
Review cadence and stamp together
A normal arrival rate can carry old stamps. Retain observation time, message stamp and frame pair, then align the failing interval with the activity of each edge.
Add producer-side evidence
For the suspected edge, inspect acquisition, transform creation and publication times. A slow receiving-side update does not localize the delay to the device, software queue or transport by itself.
Compare matched workloads
Retain normal and busy recordings for the same path, holding message size and startup settings comparable. If instrumentation changes, account for the workload it adds.
Deliver the evidence window
Keep the path, suspected edge, samples and observation interval. Mark unresolved stages. A delayed graph edge describes an observed boundary, with endpoint records needed for deeper localization.
Original documentation and further reading
Continue with related articles in this section, or use selection guides to prepare the next review. Apply the device-specific documentation and agreed operating conditions when implementing a test.