
Verify a Placed Part Returns to the MoveIt World Scene
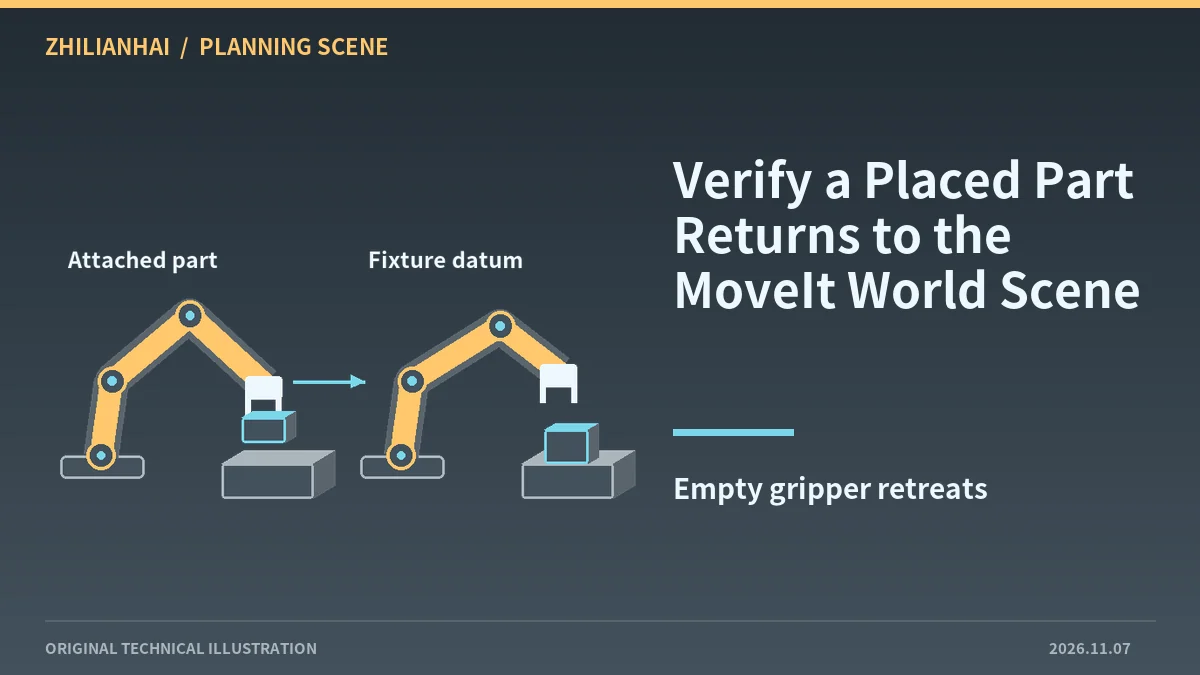
Identify release confirmation
Distinguish the release command, gripper confirmation and scene update. Record the event that triggers detachment so the observer can explain temporary differences between physical and planning state.
Pair removal and world placement
The tutorial removes the attached object and adds a world object. Review ID, geometry and operation in the actual payload, guarding against an object disappearing or being represented twice.
Express the placed pose
Tie the world pose to the receiving fixture datum. Retain the robot pose and transform used to express it. Replacing the frame label on wrist-relative coordinates does not relocate the numeric pose correctly.
Observe retreat after release
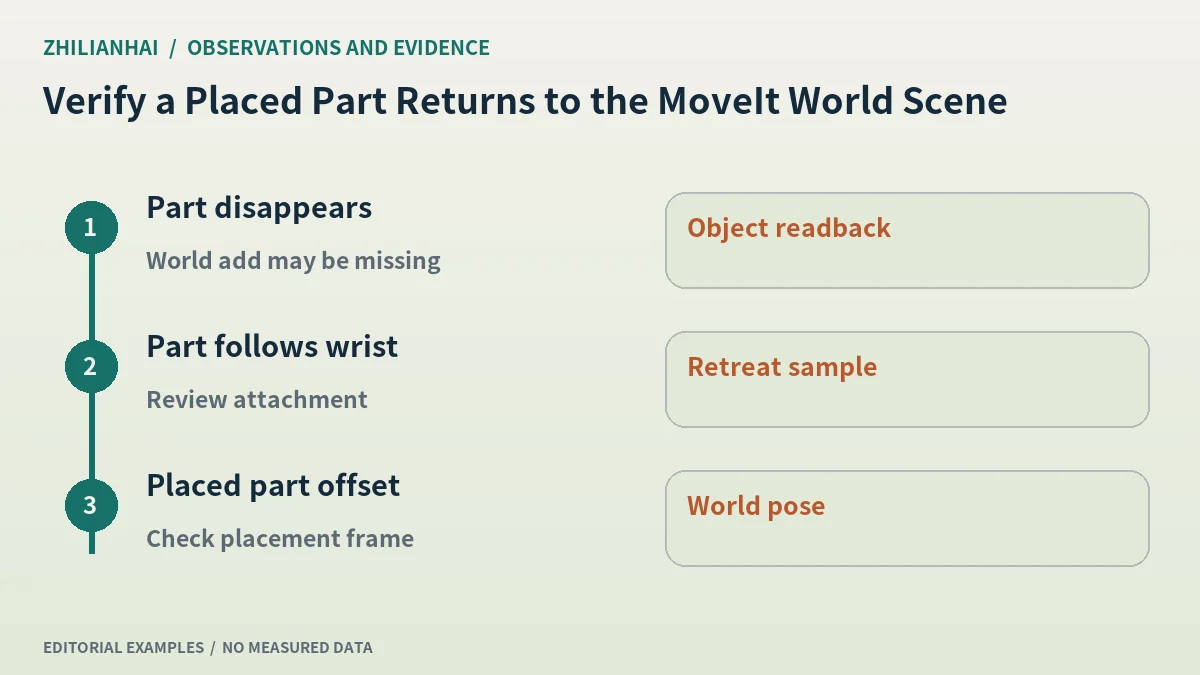
Move the wrist away in an offline scene. Verify the part remains in the world set and no longer follows the gripper. Keep object-set readback and pose evidence beyond the release instant.
Review recovery
If only part of the transition succeeds, retain an unresolved state and read the scene back before correcting it. Document how repeat messages differ from a new placement attempt.
Original documentation and further reading
Continue with related articles in this section, or use selection guides to prepare the next review. Apply the device-specific documentation and agreed operating conditions when implementing a test.