
Review Touch Links for Attached Robot Parts
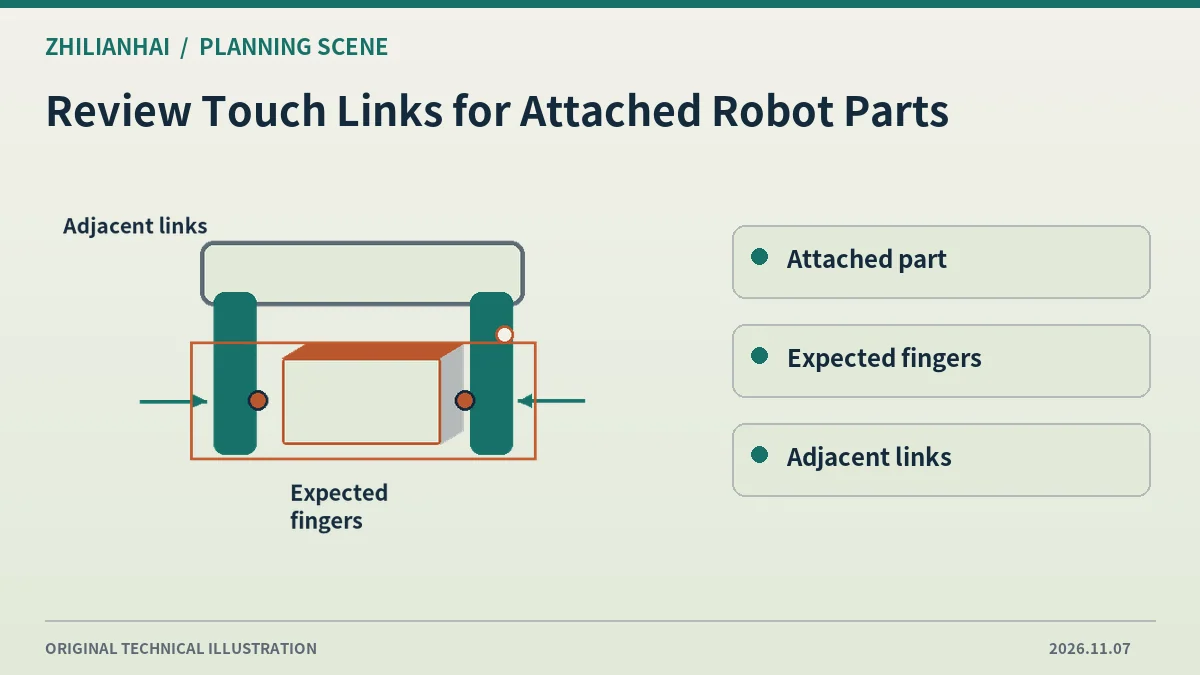
Start with actual contact faces
Map the expected part contacts to actual links in the robot model. A commercial gripper name alone does not identify the links representing its palm, fingers and adapters.
Read effective attachment configuration
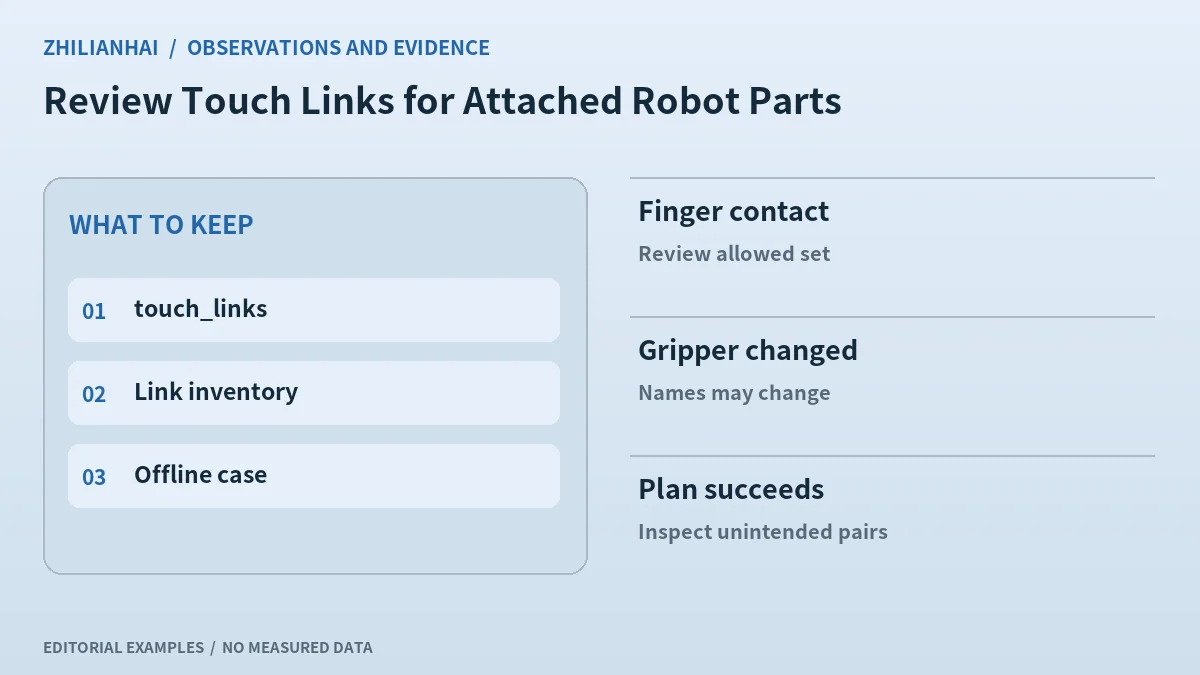
The example lists links that may touch the attached object. Retain the effective touch list and attachment link. After a gripper change, verify the names still refer to the intended components.
Separate contact rules from geometry
Allowing a contact does not change the shape of the model. Review part size, pose and collision geometry alongside other rules such as the effective collision matrix.
Use two contrast cases
In an offline model, review expected finger contact and proximity to an unintended link. Retain the contact pairs and checker output rather than using one successful plan as coverage of every contact rule.
Deliver revisions and rationale
Keep part, gripper and robot model versions. Record why each link appears in the allowed set. Investigate geometry or frame errors before expanding exceptions.
Original documentation and further reading
Continue with related articles in this section, or use selection guides to prepare the next review. Apply the device-specific documentation and agreed operating conditions when implementing a test.