
Document Topic Names Across a Gazebo-to-ROS Bridge
Record both actual names
Read the topic in the active world and model scope, then the full name used by the ROS consumer. Display labels alone do not establish transport identities.
Inspect the configured pair
The Harmonic YAML example supplies separate ros_topic_name and gz_topic_name fields. Retain the loaded file and resolved names, identifying how relative names acquire a namespace.
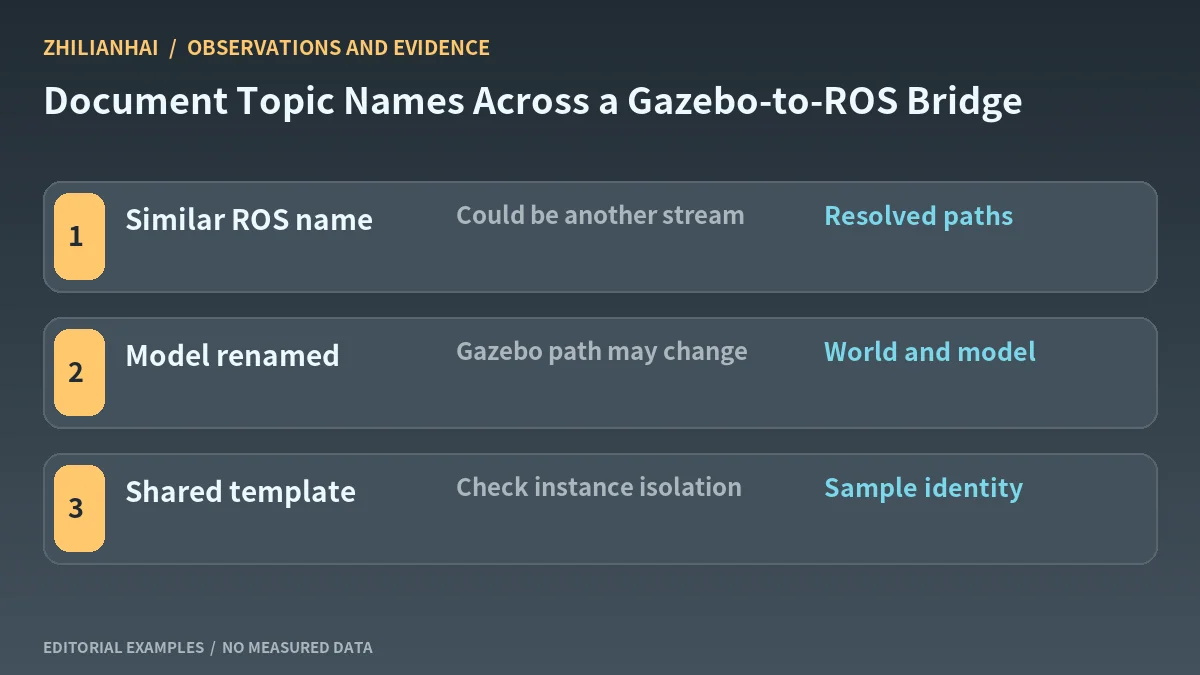
Avoid cross-robot name collisions
Robot instances can share a template while using different world or model prefixes. Confirm that a sample for one instance reaches its intended consumer and retain identity on both sides.
Verify routing with an actual sample
Trace an identifiable sample in isolated simulation, including resolved names, types and contents. Matching type lists alone can conceal attachment to another stream of the same type.
Deliver the mapping and naming history
Keep world, model, ROS namespace and mapping source. Recheck after cloning or renaming environments so the integration remains explainable outside its original instance.
Original documentation and further reading
Continue with related articles in this section, or use selection guides to prepare the next review. Apply the device-specific documentation and agreed operating conditions when implementing a test.